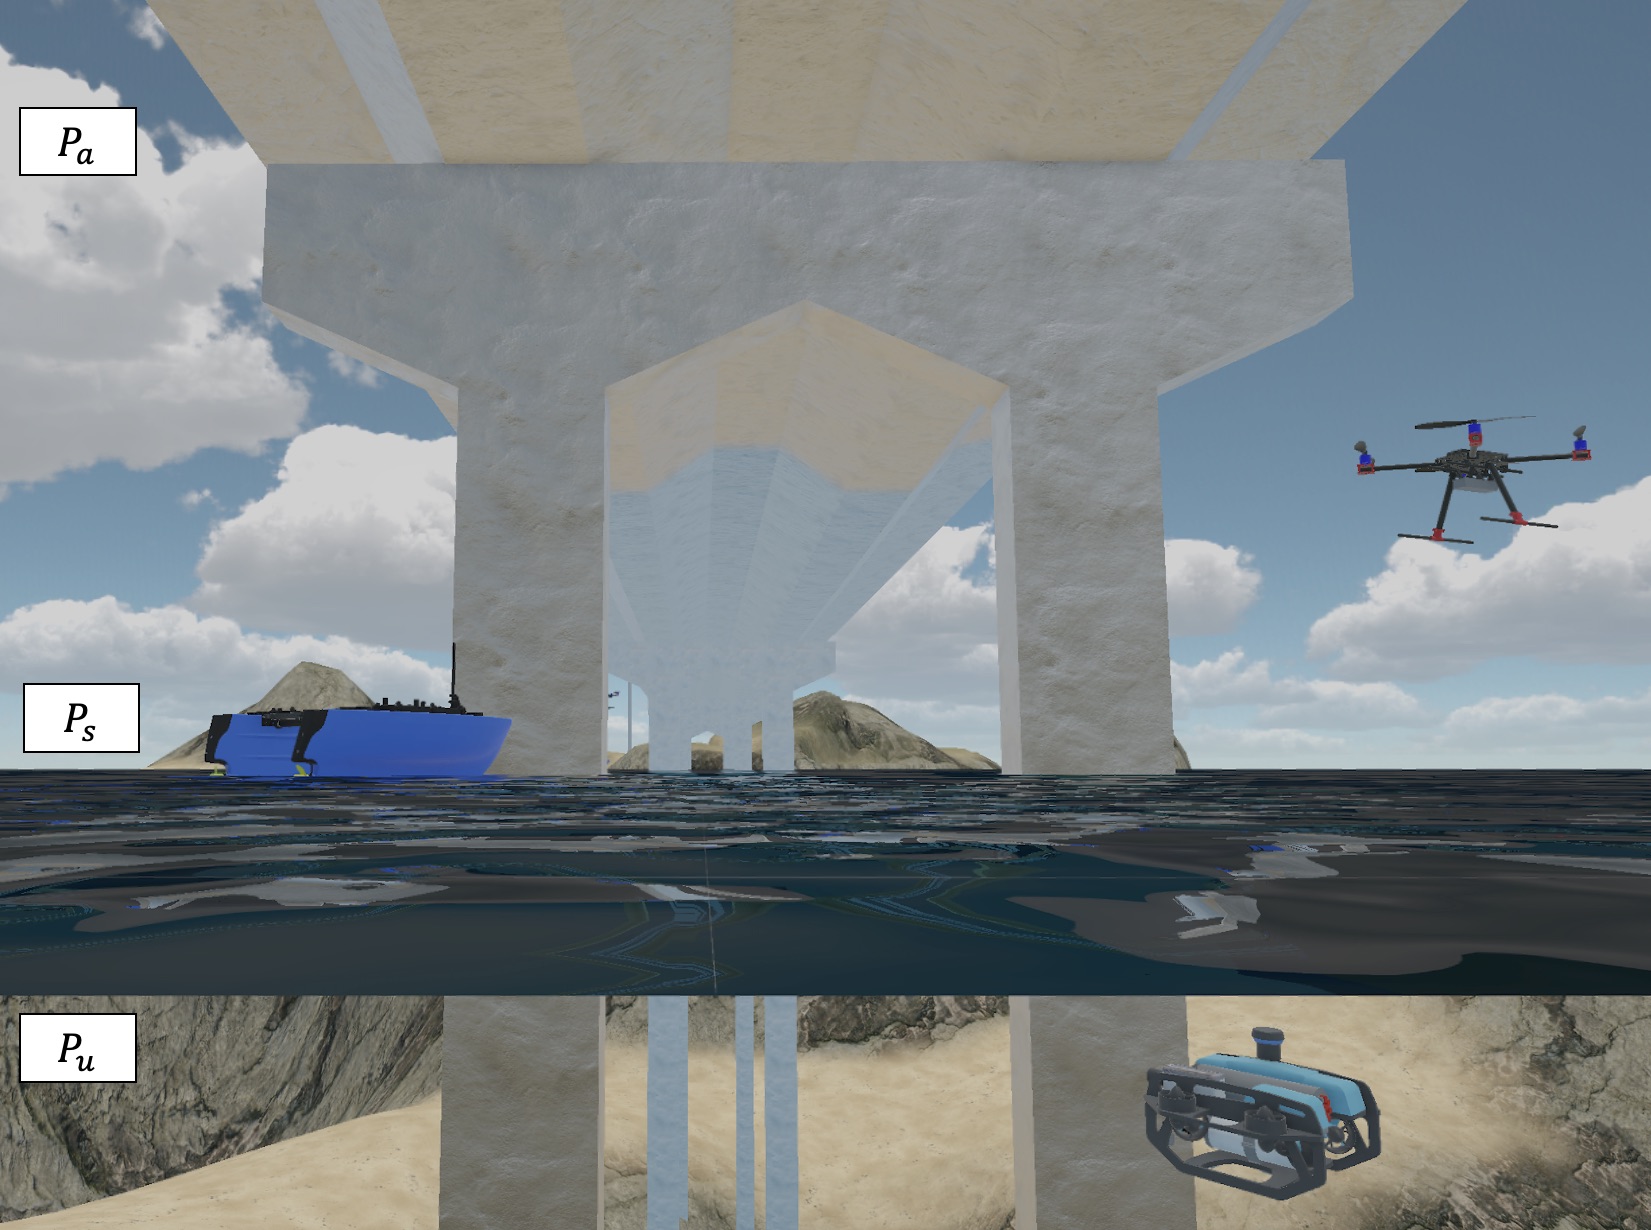
Building autonomous underwater, surface, and aerial robotic systems for critical infrastructure resilience and environmental monitoring.
As a dedicated Roboticist, I am actively involved in advancing AI, robotics, and machine learning through innovative research and real-world application. My current work focuses on developing autonomous underwater, surface, and aerial robotic systems for infrastructure and environmental monitoring.
I have experience in geospatial planning, autonomous navigation, environmental sensing, robotic system integration, hydrodynamic analysis, simulation, and field validation with ASV and ROV platforms.
Beyond research, I continue to build practical systems through side projects such as CNC machines and 3D printers, using tools like GRBL, Fusion 360, and additive manufacturing to fabricate custom parts and prototypes.
TensorFlow, YOLO, Federated Learning, Differential Privacy, Multi-Agent Systems, RL
ROS, Isaac Lab/Sim, Arduino, QGroundControl, BlueRobotics, Hycat Controls
Python, C++, NumPy, Pandas, Matplotlib, Docker, Fusion 360
MBSE, Google Cloud, Windows Server, Security Analysis, Project Management
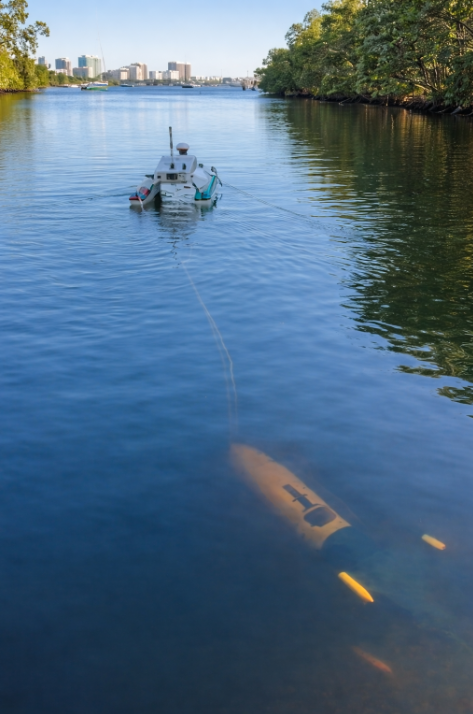
Adaptive coverage algorithms for autonomous marine sensing across drones, AUVs, and surface vehicles. Validated through CFD analysis and real-world ASV/ROV field deployments.
Multi-agent systems for autonomous monitoring and critical infrastructure resilience. Privacy-preserving data collection using differential privacy for heterogeneous marine robot teams.
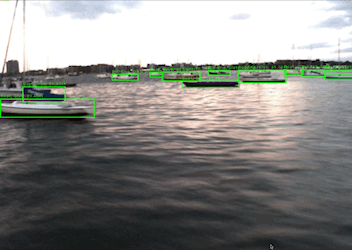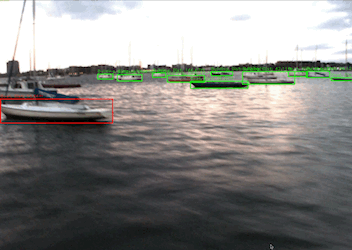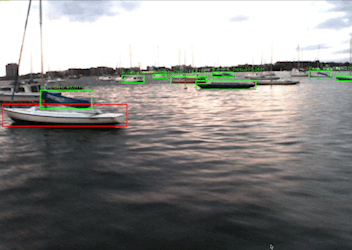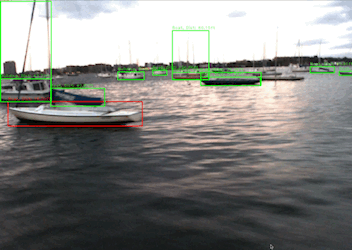
CNN-based vessel detection from electro-optical and synthetic aperture radar imagery with decision-tree collision avoidance for autonomous navigation.
Local-first, multi-agent AI assistant with 13 specialized agents, local LLM orchestration, web dashboard, voice interface, and 800+ test suite. Containerized with Docker.
Autonomous Underwater Vehicle platform with ROS integration, autonomous navigation, reinforcement learning pipelines, and real-world field deployment support.
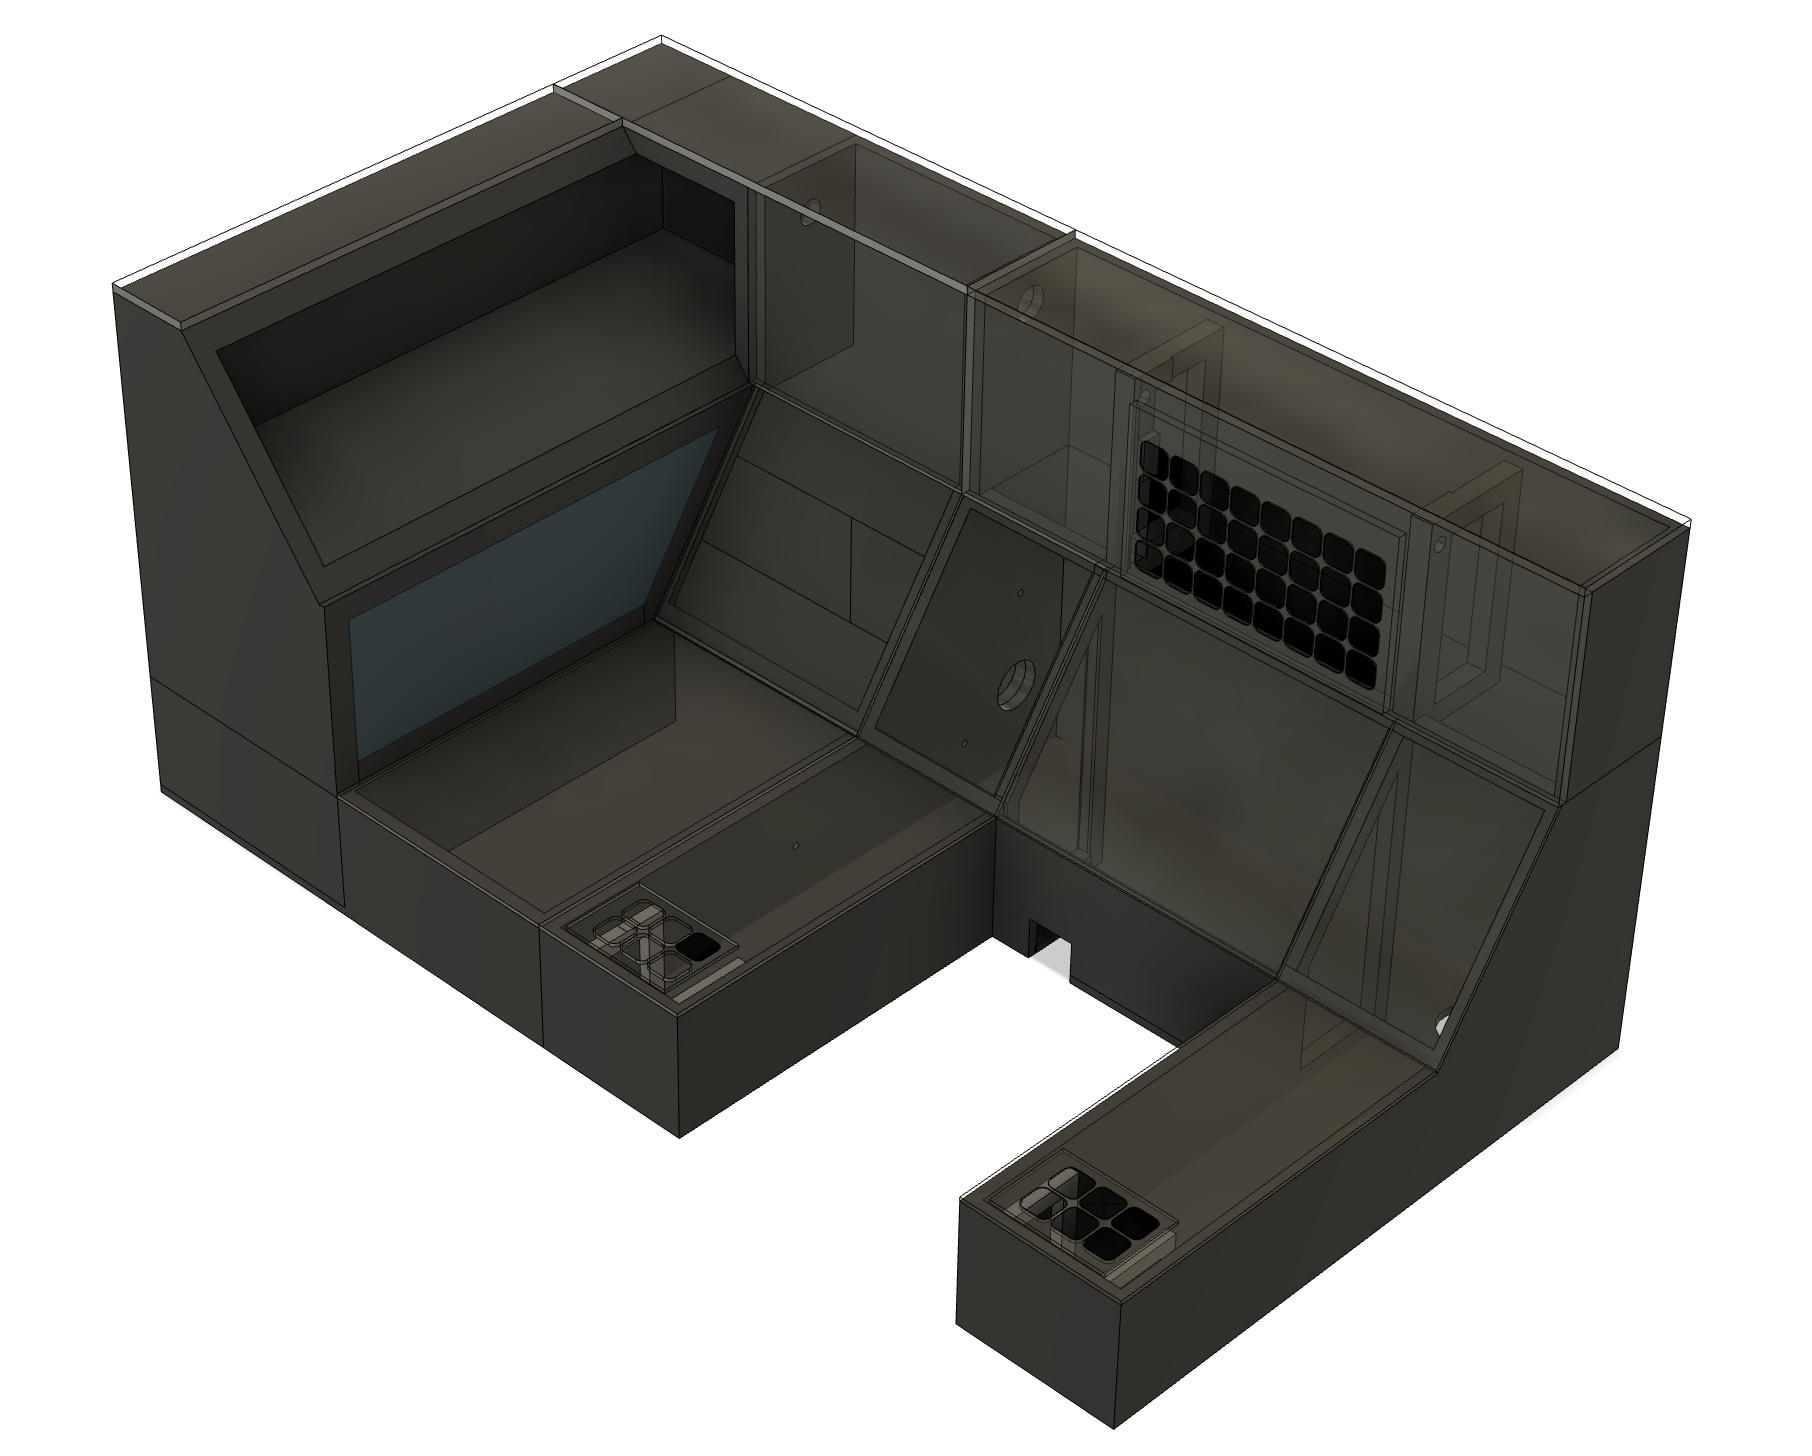
Flight simulator console, CNC machine cabinet, 3D printer integration, and custom robotics parts fabricated using modern CAD and additive manufacturing tools.
OCEANS 2025 — Great Lakes, Chicago, IL, USA, 2025, pp. 1-8
DOI: 10.23919/OCEANS59106.2025.11244994
OCEANS 2023 — MTS/IEEE U.S. Gulf Coast, Biloxi, MS, USA, 2023, pp. 1-10
DOI: 10.23919/OCEANS52994.2023.10336953
IEEE/RSJ IROS, Pittsburgh, PA, USA, 2026
Northrop Grumman
Apply AI/ML techniques to systems modeling and simulation workflows supporting MBSE. Develop validated simulation environments for mission-critical autonomous platforms.
Florida International University — MORA LAB, SOLID LAB, CREST, IoE
Design event-triggered coverage planning algorithms. Manage research teams and validate mission-level trade-offs via CFD and field deployments.
Naval Research Lab
Developed locomotion models for Boston Dynamics Spot in IsaacLab. Enhanced OceanSim with simulated EBS camera for underwater vision.
Wright-Patterson Air Force Base
Research in autonomous systems and robotics technologies.
NAVSTA Guantanamo Bay, Cuba
U.S. Navy veteran. Good Conduct Medal, National Defense Medal, Global War on Terrorism Medal.